


Txhuam motors thiab brushless motors, raws li ob hom kev tsav tsheb tseem ceeb hauv kev lag luam niaj hnub thiab cov neeg siv khoom siv hluav taws xob, muaj cov txheej txheem xaim uas cuam tshuam ncaj qha rau cov khoom siv hluav taws xob, kev ruaj ntseg, thiab kev ua neej nyob. Tsab ntawv xov xwm no txheeb xyuas cov ntsiab cai ntawm kev xaim, cov kauj ruam ua haujlwm, thiab cov pitfalls rau ob lub cev muaj zog, muab kev cob qhia kev cob qhia kom haum rau kev siv cov xwm txheej.
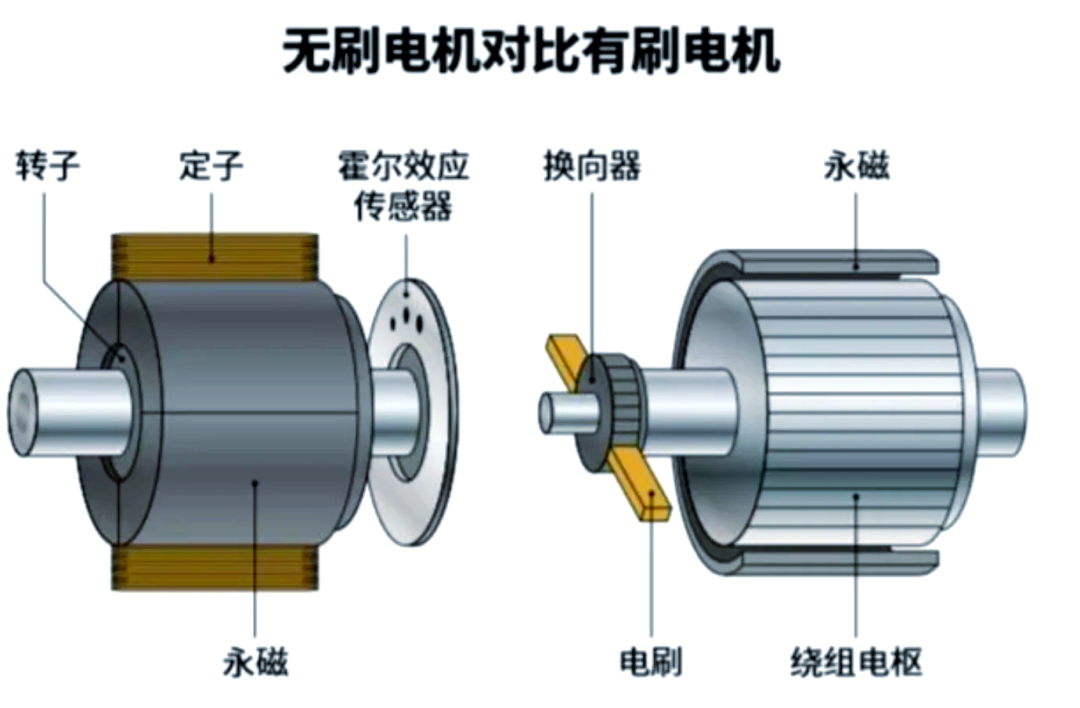
I. Txhuam lub cev muaj zog thaiv cov ntsiab lus thiab siv tau
Txhuam motors siv mechanical commutators (carbon txhuam) los hloov cov kev taw qhia tam sim no. Lub hauv paus ntawm kev xaim yog nyob rau hauv kom raug txuas cov stator windings rau lub rotor armature. Cov kauj ruam txuas ib txwm rau ob - xaim DC txhuam lub cev muaj raws li hauv qab no:
1. Kev txheeb xyuas lub zog polarity:Txuas cov xaim liab mus rau lub davhlau ya nyob twg zoo (+) ntawm lub zog hluav taws xob thiab cov hlau dub rau lub davhlau ya nyob twg tsis zoo (-). Yog hais tias lub cev muaj zog rotates nyob rau hauv lub opposite kev taw qhia, tsuas yog swap ob lub terminals kom thim rov qab.
2. Sab Nraud Ceev Tswj Kev Sib Txuas:Thaum kho ceev, txuas lub PWM ceev maub los nyob rau hauv series ntawm lub hwj chim mov zoo davhlau ya nyob twg thiab lub cev muaj zog. Xyuas kom tus maub los qhov ntsuas tam sim no phim lub cav lub zog ntsuas. Piv txwv li, 12V / 5A brushed lub cev muaj zog yuav tsum muaj kev tswj xyuas nrawm nrog qhov ntsuas tam sim no ntau dua lossis sib npaug rau 6A.
3. Kev tiv thaiv Circuit Court Installation:Nws raug nquahu kom txuas lub diode rov qab (piv txwv li, 1N4007) nyob rau hauv tib lub sijhawm ntawm lub hwj huam mov kawg kom nqus tau rov qab EMF tsim tawm thaum lub sij hawm armature de-energization, tiv thaiv tus neeg tsav tsheb Circuit Court breakdown.
Common Misconceptions:
● Kev sib txuas ncaj qha rau siab- lub zog lub cev muaj zog rau qis- cov khoom siv hluav taws xob muaj peev xwm ua kom cov pa roj carbon txhuam kom muaj zog thiab ua rau lub neej luv.
● Kev tsis saib xyuas hauv av, ua rau muaj kev cuam tshuam electromagnetic. Kev xyaum kom raug: Txuas lub cev muaj zog hlau vaj tse rau cov khoom siv hauv av los ntawm cov kab daj -ntsuab ntsuab.
II. Brushless Motor Wiring Analysis
Brushless motors (BLDC) siv hluav taws xob sib hloov, yuav tsum muaj cov tswj kom ua raws lub zog mus rau peb -theem windings. Siv peb yam -theem brushless lub cev muaj zog ua piv txwv:
1. Phase Matching:Txuas lub cev muaj zog UVW theem xaim mus rau cov chaw nres nkoj sib xws. Yog tias kev sib hloov tsis raug, tsuas yog hloov ob theem xov hlau (piv txwv li, U-V). Qee qhov siab - kawg controllers txhawb software theem hloov, tshem tawm phau ntawv rewiring.
2. Hall Sensor Wiring:Rau BLDC motors nrog Hall tawm tswv yim, phim tag nrho tsib lub teeb liab xov hlau (liab / dub rau lub zog, daj / ntsuab / xiav rau cov teeb liab) rau tus maub los. Siv lub tshuab ntsuas ntau los txheeb xyuas Hall sensor fais fab mov voltage (feem ntau 5V) rau kev txuas mus txuas ntxiv.
3. Controller Configuration:
● Fais fab tso zis: 48V controllers yuav tsum sib piv 48V lithium roj teeb pob. Tsis txhob txuas cov khoom siv hluav taws xob ntau tshaj 20% ntawm qhov ntsuas hluav taws xob.
● Teeb liab Interface: Kev tswj ceev cov teeb liab xaim (feem ntau yog dawb) txais 0-5V analog voltage lossis PWM cov teeb liab. Qee cov qauv txhawb USB parameter programming.
Kev ceev faj tseem ceeb:
● Phase Loss Protection: Peb tsis raug -theem thaiv ua rau lub cev muaj zog vibration lossis winding burnout. Txheeb xyuas qhov sib npaug waveforms thoob plaws txhua theem nrog oscilloscope ua ntej lub hwj chim.
● Sensor Calibration: Ua Hall sensor xoom-point calibration thaum pib ua haujlwm (xws li, lub zog rau 5 vib nas this nrog lub cev muaj zog nyob ruaj khov). Xa mus rau tus maub los phau ntawv qhia tshwj xeeb.
III. Daim ntawv thov Scenario Sib piv thiab xaiv cov lus pom zoo
1. Daim ntawv thov rau Brushed Motors:
● Tsawg- tus nqi yuav tsum:Qhov zoo tshaj plaws rau cov menyuam yaus cov khoom ua si thiab cov kiv cua hauv tsev, siv lawv cov qauv yooj yim thiab tus tswj hwm - ua haujlwm dawb.
● Instantaneous overload scenarios:Thaum lub sijhawm pib / nres kev hloov pauv ntawm cranes, brushed motors siv cov pa roj carbon txhuam kom tsis txhob surges tam sim no.
2. Qhov zoo ntawm Brushless Tsav:
● High- tswj qhov tseeb:Drone ESCs ua tiav millisecond- theem teb ntawm 400Hz refresh tus nqi.
● Ntev - lub voj voog ua haujlwm:Kev lag luam robotic caj npab siv brushless kev daws teeb meem tshem tawm cov pa roj carbon txhuam hloov kho, nrog rau kev ua neej ntev tshaj 20,000 teev.
IV. Advanced Debugging Techniques
1. Oscilloscope Diagnostics:
●Brushed Motors:Saib xyuas lub zog mov ripple. Yog tias qhov siab tshaj - txog - ncov tshaj 10% ntawm qhov ntsuas hluav taws xob, ntxiv LC lim circuit.
●Brushless Tsav:Khaws rov qab -EMF waveforms. Kho tus maub los PID tsis yog theem qeeb tshaj 15 degree.
2. Thermal Management Solutions:
●Brushed Motors:Nruab cov dab dej kub (piv txwv li, 3mm tuab aluminium alloy) ntawm cov txhuam hniav. Kev khiav hauj lwm kub yuav tsum tsawg dua los yog sib npaug li 85℃.
●Brushless Tsav:Yog tias winding kub nce siab tshaj 60K, tshuaj xyuas kom muaj kev poob siab tam sim no vim kev xaim tsis raug.
V. Kev ruaj ntseg Specifications thiab Standards
● Kev Ntsuas Hluav Taws Xob: After all wiring is complete, measure the insulation resistance between conductors and ground using a 500V megohmmeter. A resistance value >2MΩ tau txais.
● Kev Saib Xyuas Dynamic:Nruab tam sim no transformers los saib xyuas cov theem tam sim no hauv lub sijhawm. Tam sim ntawd kaw thiab tshawb xyuas yog tias qhov kev hloov pauv txawv txav ntau dua 15%.
Txoj kev xaim hluav taws xob uas tau teev tseg saum toj no ua rau qhov ua tau zoo ntawm ob lub cev muaj zog. Rau cov kev siv nyuaj (xws li, hluav taws xob tsav tsheb), electromagnetic teb optimization siv cov cuab yeej simulation zoo li ANSYS Maxwell tau pom zoo kom ua tiav ob qho kev txhim kho hauv kev siv hluav taws xob thiab kev ntseeg siab.